Smart Garbage
Automated Wet & Dry Waste Classification Engine
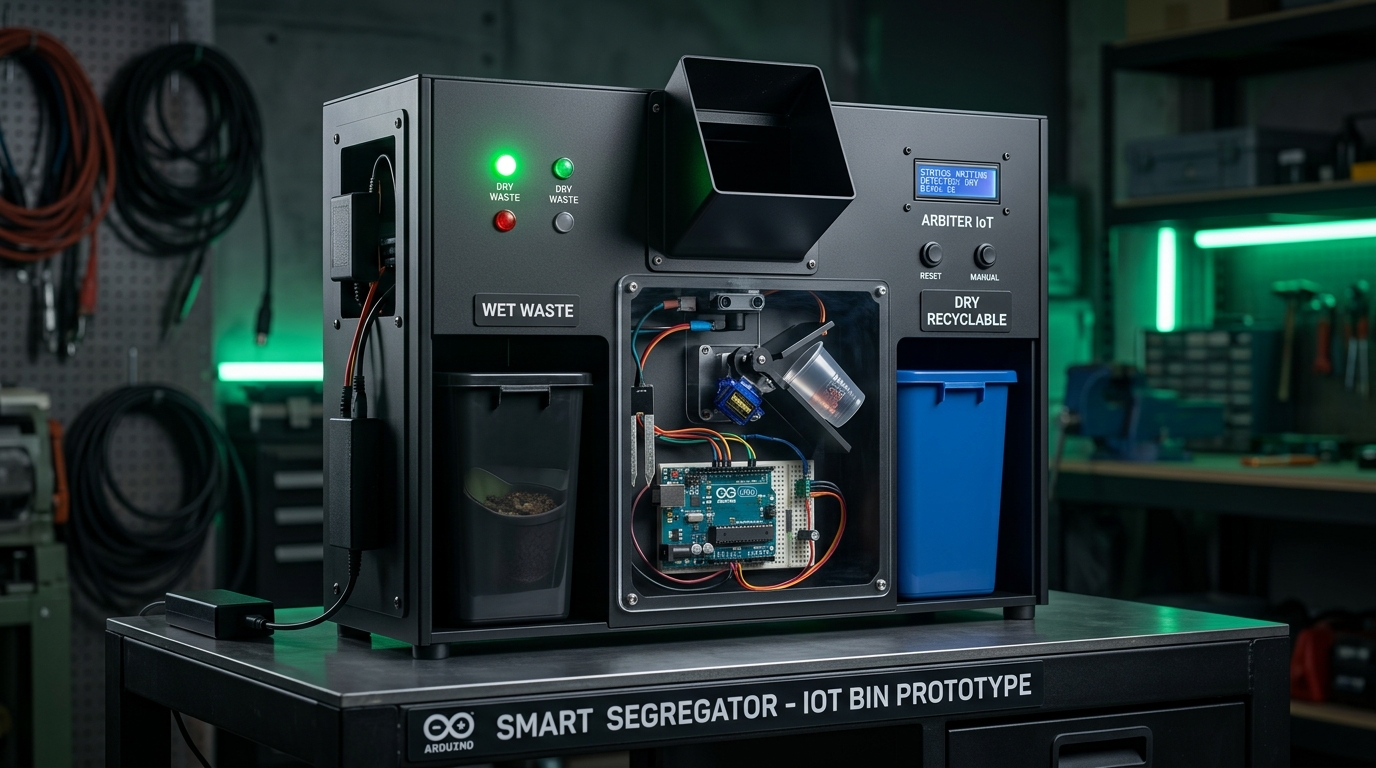
Microcontroller-based IR proximity detection, 5-sample analog moisture thresholding, and SG90 servo motor chute deflection engineered under the Ugam Campus Alchemist Protocol.
4-Step Classification Sequence.
Real-time hardware pipeline ensuring accurate wet vs dry separation in under 50 milliseconds.
IR Proximity Approach
Active IR sensor detects incoming waste item at chute entrance on Digital Pin 2, triggering microsecond interrupt.
Analog Moisture Probe
Soil moisture probe polls Analog Pin A0 across 5 consecutive samples (50ms window) to eliminate static ADC noise.
PWM Servo Routing
SG90 servo motor deflects chute to 20° for Wet Waste (Moisture < 950) or 160° for Dry Waste (Moisture ≥ 950).
Feedback & Auto-Reset
Flashes Green/Red LED, sounds active tone buzzer, and automatically returns servo to 90° center home after 3 seconds.
Classification Speed
Instant object detection via IR proximity sensor coupled with 5-sample analog moisture averaging to eliminate sensor noise. Engineered under the Ugam Campus Alchemist Protocol.
Hardware Schematic & Bill of Materials.
IR Proximity Sensor Module
Active infrared transmitter and receiver pair calibrated to detect waste items within 5cm of chute entrance.
Soil Moisture Sensor Probe
Dual conductor probe calculating electrical conductivity of waste. Values < 950 indicate high moisture content.
SG90 Micro Servo Motor
1.8kg-cm torque micro servo positioning the waste divider flap between Wet (20°), Home (90°), and Dry (160°).
Green & Red Status LEDs
Visual indicator lights giving immediate status feedback to users during classification.
Piezo Audio Buzzer
Audio confirmation tone triggered upon successful waste detection and chute deflection.
Arduino Microcontroller
Central embedded controller executing C++ firmware with 16MHz clock speed and 10-bit ADC conversion.
Microcontroller Firmware & PWM Control.
Manual waste segregation is inefficient and hazardous. As a flagship Ugam Campus product project, the Smart Garbage System detects incoming waste at the chute using an active IR sensor, polls soil moisture levels across 5 consecutive samples, and routes the waste into dedicated wet (20°) or dry (160°) compartments via an SG90 servo motor.
// Read 5-sample averaged moisture content
int moistureValue = 0;
for (int i = 0; i < 5; i++) {
  moistureValue += analogRead(MOISTURE_PIN);
  delay(10);
}
moistureValue /= 5;

// Classify & Route Waste Chute
if (moistureValue < MOISTURE_THRESHOLD) {
  // Wet Waste Path (20 degrees)
  digitalWrite(LED_GREEN_PIN, HIGH);
  binServo.write(SERVO_WET_ANGLE);
} else {
  // Dry Waste Path (160 degrees)
  digitalWrite(LED_RED_PIN, HIGH);
  binServo.write(SERVO_DRY_ANGLE);
}